Shivam Goel
Postdoctoral Scholar, University of Alberta
I am an incoming postdoctoral scholar at the University of Alberta and Amii, working with Matt Taylor in the IRL Lab. I am also affiliated with RLAI.
I recently completed my Ph.D. in Computer Science at Tufts University with a focus on AI and Robotics, where I worked with Jivko Sinapov and Matthias Scheutz. My dissertation explored how structured abstractions can help robots to learn and adapt when facing novelty in open-world environments.
Research interests: open-world robotics, human–robot interaction, and reinforcement learning for robotics.
My long-term goal is to build autonomous robots that can handle the unexpected and efficiently learn, adapt, and improve by observing our daily lives — not just tools, but lifelong collaborators in our homes and workplaces. Know more about my research →
News
Research
My research aims to advance AI and robotics for open-world environments, where novelty, uncertainty, and unstructured interactions are the norm. A central focus is force-space manipulation, grounding policies in physical interaction and object-centric representations to transfer across robot embodiments. By combining learning, planning, and structured object models, I build frameworks and algorithms that unify high-level reasoning with low-level control aiming toward autonomous robots that thrive in dynamic real-world settings.
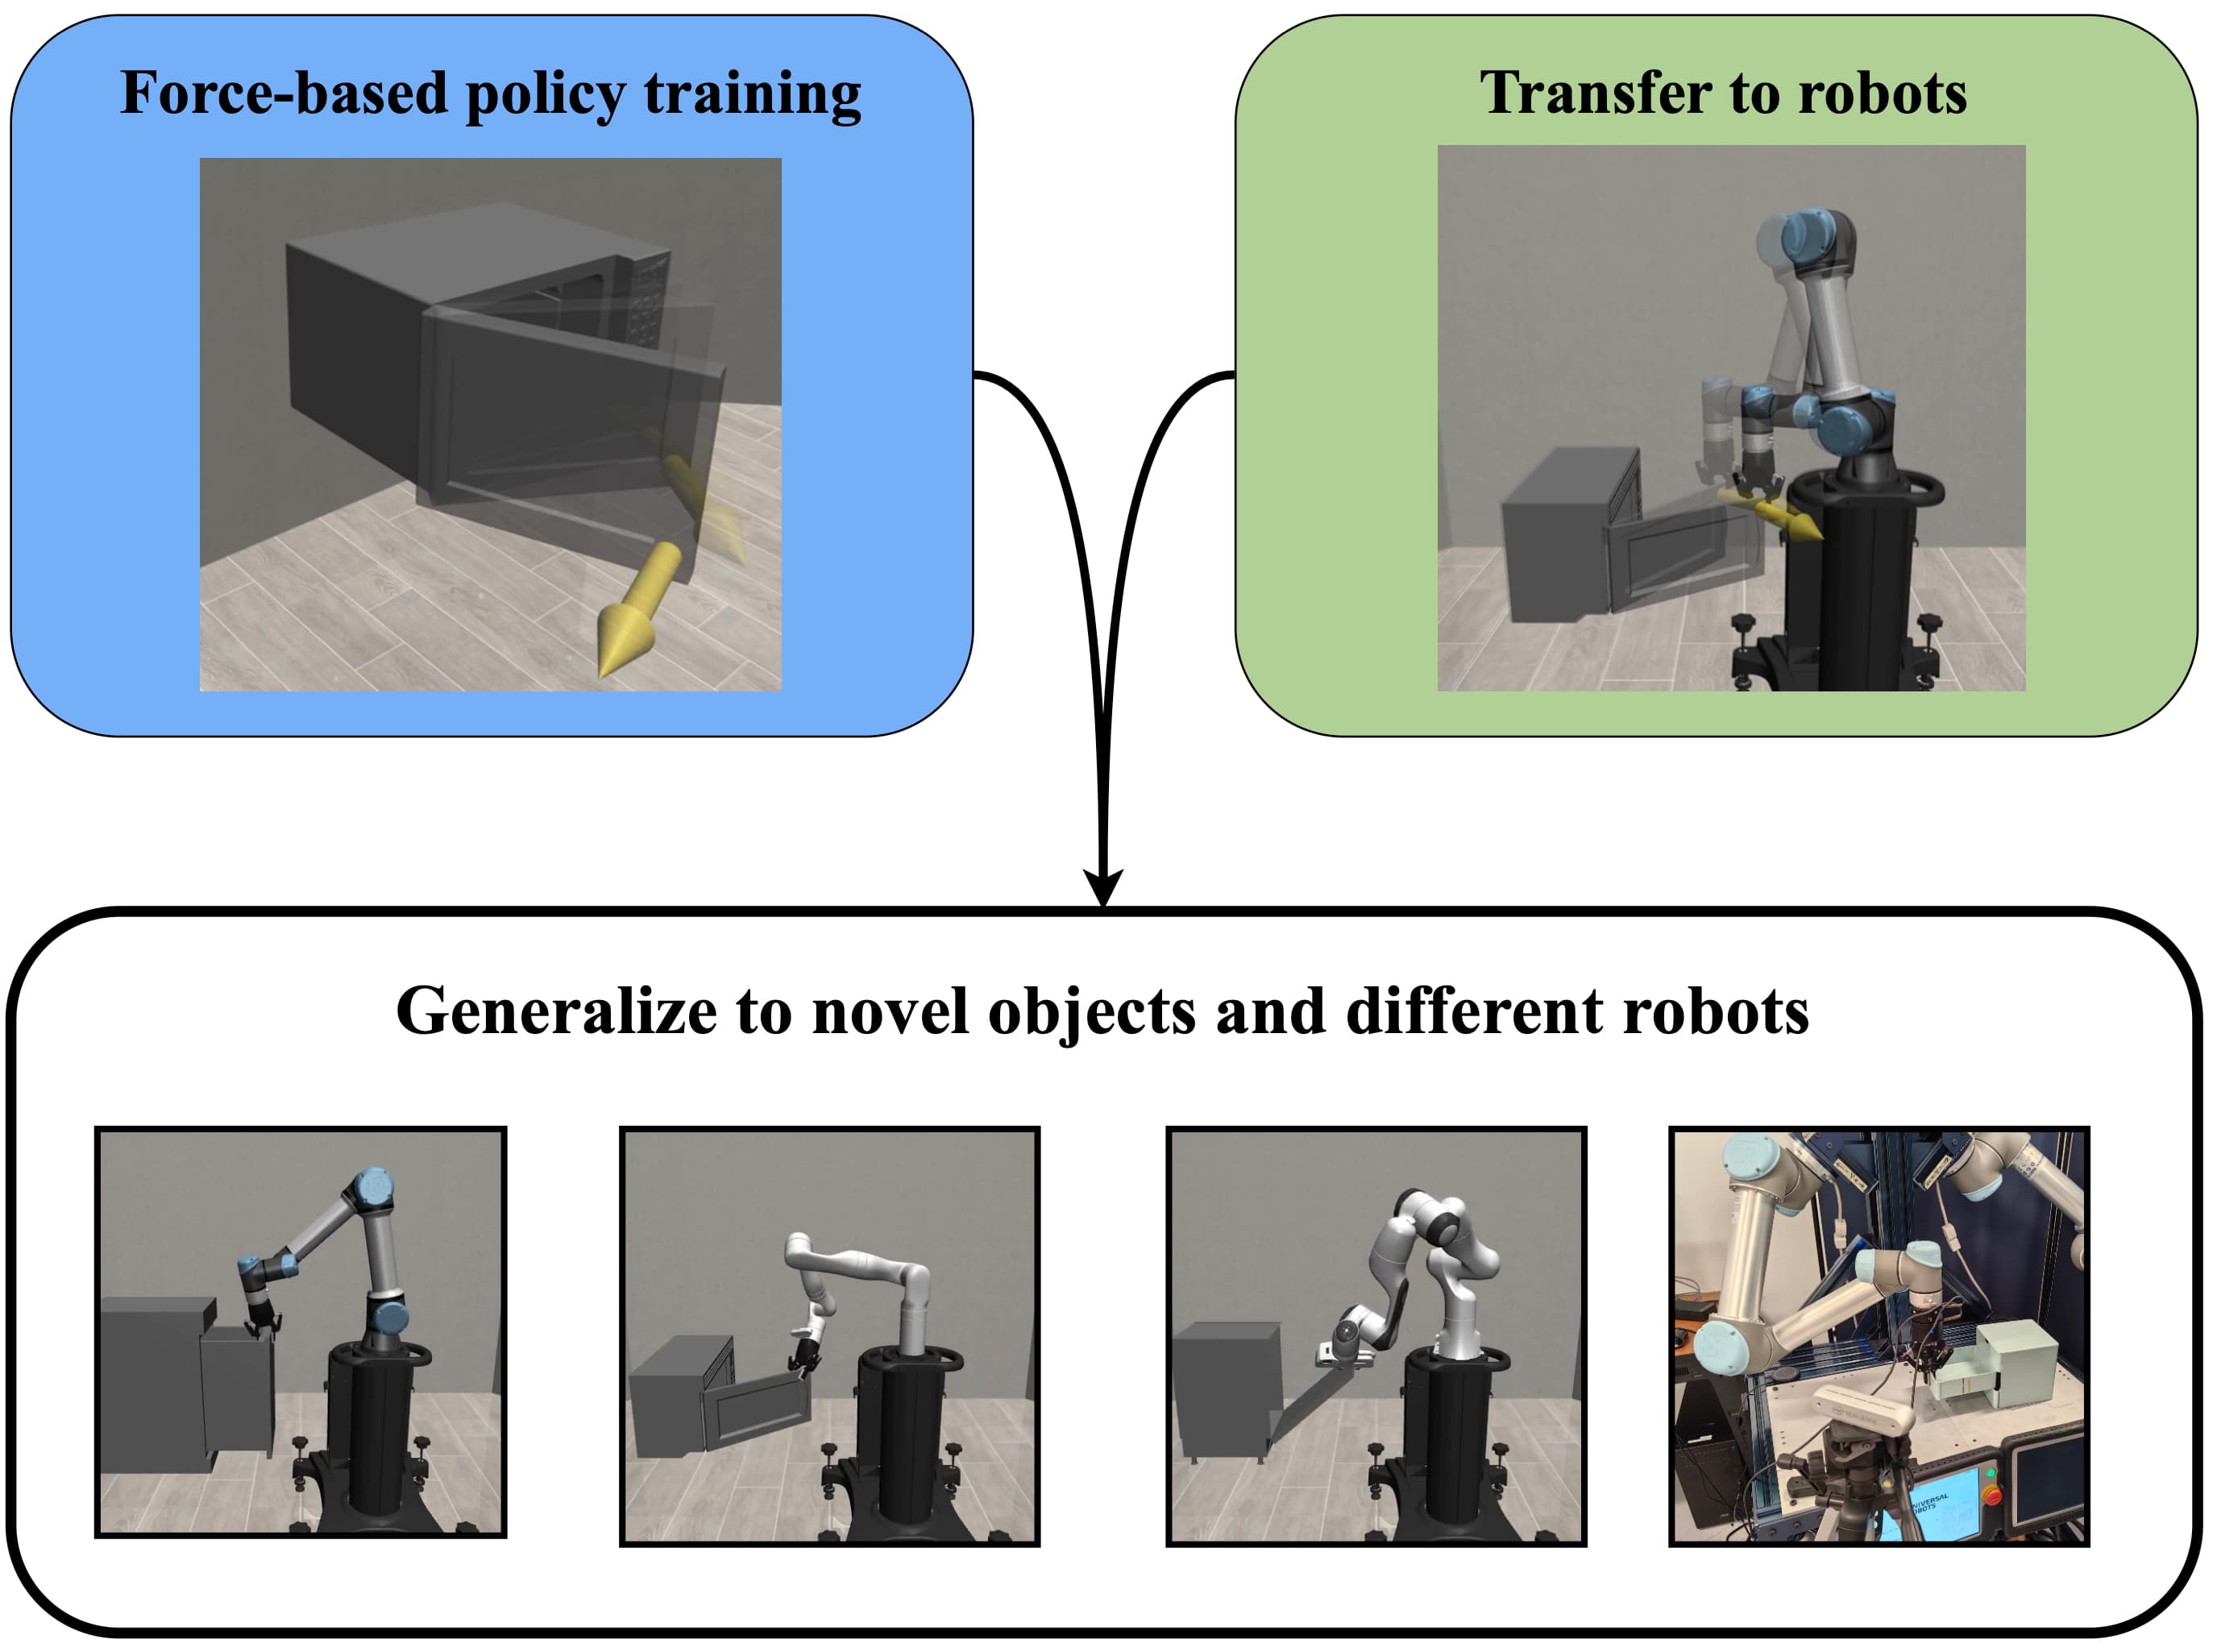
Robot-agnostic policies; sim→real (Spot/UR5/Panda/Kinova).
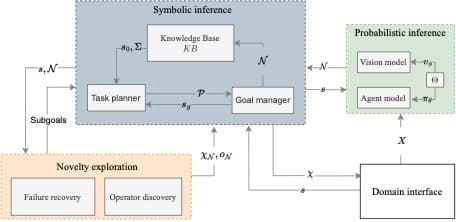
Reasoning + RL for novelty detection, adaptation, and recovery.
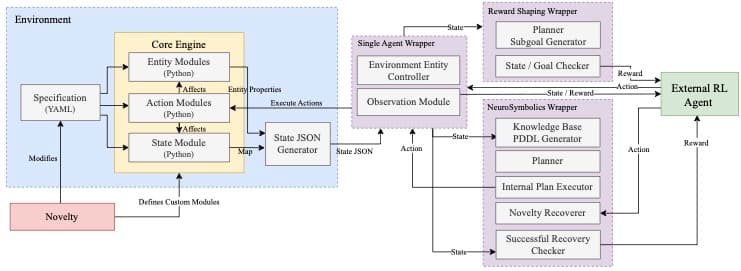
NovelGym and evaluation suites for hybrid planning+RL agents.